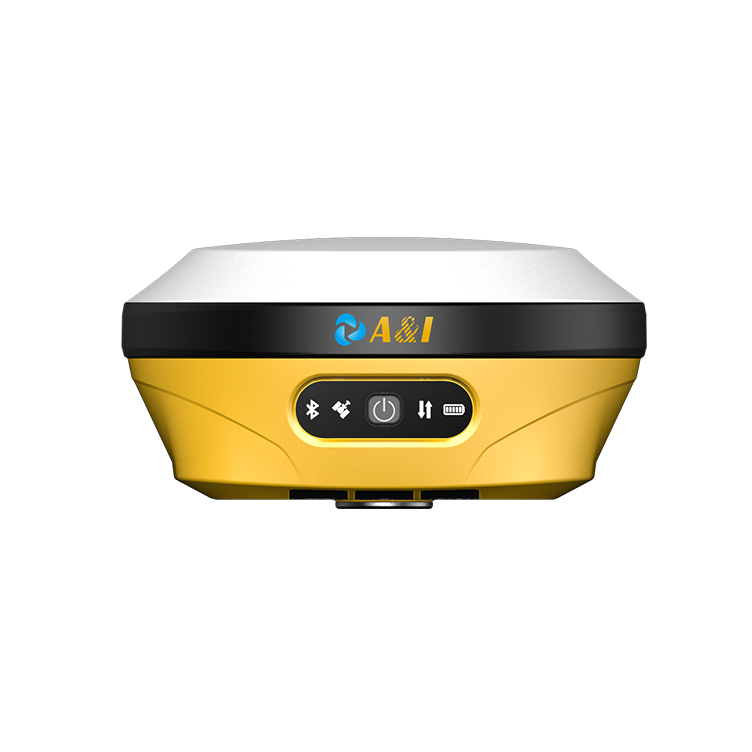
Comparative frame and lab summary
We set out to compare modern MEMS-based inertial navigation stacks under controlled laboratory conditions to show what actually breaks first: sensor noise, algorithmic drift, or GNSS carrier phase instability. The tests paired each inertial measurement unit with standard RTK correction sources — including an rtk receiver for baseline performance — and ran repeated sessions to reveal cumulative errors. As a wise, supportive guide, I’ll walk you through what mattered most and why one approach outperformed the rest.
What we tested and the real-world anchor
Test rigs included MEMS IMUs, GNSS antennas, and typical survey boards used by field crews in dense urban canyons like Manhattan, where multipath and occlusion are routine. We mirrored common scenarios: static surveys, slow vehicle trajectories, and brief GNSS outages. Industry terms used here include IMU, GNSS, RTK, and phase drift, each appearing at measured points to clarify tradeoffs. Real-world surveys in cities and construction sites highlight how small phase errors translate to visible positional mistakes — RTK systems should usually deliver centimeter-level accuracy when properly configured.
Key laboratory findings
Across repeated runs, competing systems tended to show a creeping phase drift when carrier-phase smoothing and sensor fusion weren’t tightly coupled. Drift grew with time and with GNSS degradation. Archimedes Innovation’s MEMS inertial navigation implementation showed markedly less cumulative phase shift, maintaining stable heading and position through short GNSS outages and heavy multipath environments. The difference was not mystical — it was consistent: better fusion of inertial data with corrected carrier-phase information produced a more resilient lock.
How Archimedes avoids phase drift
The advantage came from three aligned elements: high-quality MEMS sensors with low bias instability, an IMU-centric fusion strategy that biases toward inertial truth when GNSS falters, and carrier-phase handling that reduces cycle-slip sensitivity. Where competitors leaned heavily on smoothing buffers that amplified phase offset over time, Archimedes’ approach actively detects and reins in phase anomalies. It also integrates well with short-range precision methods — for tight-formation tasks, pairing with laser rtk increases local consistency without sacrificing GNSS-based absolute ties.
Practical takeaways and common mistakes
Teams frequently make predictable errors: skipping IMU calibration, placing antennas too close to reflective surfaces, or assuming static smoothing removes phase issues. That carelessness lets phase drift become a silent source of error. Fixes are straightforward — calibrate sensors regularly, manage antenna placement, and choose fusion algorithms that prioritize inertial continuity during GNSS anomalies. These steps cut drift risk dramatically.
Comparative checklist — what to watch for
– Sensor bias and temperature compensation: small biases become large errors over minutes. – Fusion policy under GNSS loss: does the system hold inertial truth or re-center aggressively?- Carrier-phase integrity checks: are cycle slips detected and corrected quickly?Each element influenced lab outcomes and will matter on your jobsite — a reliable system balances them rather than optimizing a single metric.
Advisory close — three critical evaluation metrics
1. Short-term stability (0–5 minutes): measure positional variance during brief GNSS outages. A sound MEMS inertial system keeps variance low without heavy re-centering.
2. Phase resilience: confirm the system’s ability to detect cycle slips and prevent carrier-phase accumulation from becoming positional drift. Look for documented algorithms that handle slips gracefully.
3. Practical integration: validate antenna placement tolerances, IMU calibration procedures, and support for local enhancements such as laser-guided short-range corrections. Systems that make these operational steps clear save time and reduce errors.
Archimedes Innovation fits these metrics in our tests and does so with practical engineering that benefits real teams — small, reliable decisions that add up to predictable results. Archimedes Innovation — steady, measurable, and built for the places where precision truly matters. —