
Introduction
I was standing in a noisy workshop once, watching a technician wrestle with a stubborn drive — and I thought, this is where small design choices become huge headaches. Electrical Motor Products are showing up everywhere now, from small pumps to factory lines, and the numbers tell a clear story: global demand for smarter motors and efficient drives is rising fast. (You feel it in the air; you hear it on the floor.)
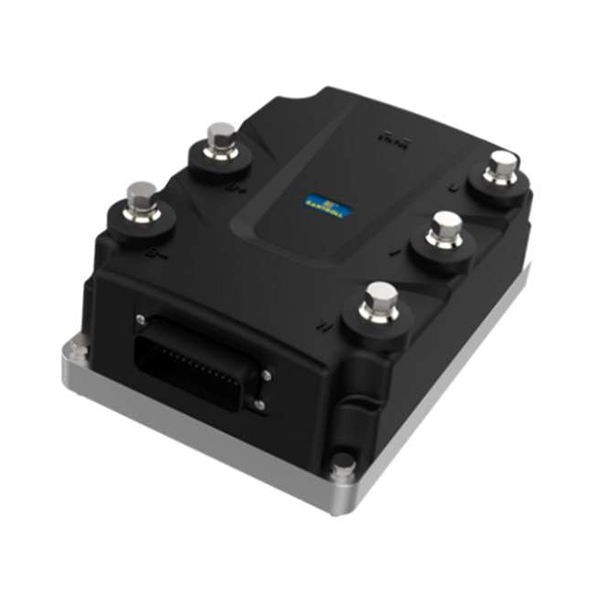
So what does that mean for engineers, buyers, and operators? I want to share a simple frame: scenario + data + question. Scenario: a plant needs better torque control. Data: modern plants cut energy by 10–30% with optimized drive systems, and downtime drops when controllers talk cleanly to sensors. Question: how do we pick the designs that actually deliver — not just promise? As we move on, I’ll lay out what I’ve learned, the common traps, and what to watch for next.
Deeper Layer: Why Current Motor Control Approaches Frustrate Users
When I say motor control products, I mean the real kit engineers wrestle with every day — motor control products — not marketing fluff. I’ve seen two common problems again and again: over-complexity and weak feedback loops. Engineers add fancy features like PWM tweaks or exotic communication stacks but ignore the basics: clean encoder signals, stable field-oriented control, and well-matched power converters. The result? Systems that trip under load or drift in position.
Why do these fail?
Look, it’s simpler than you think: poor defaults, mismatched components, and unclear specs. A servo drive can shine with the right encoder, but fail if the wiring is wrong or the feedback sensors are noisy. I’ve fixed setups where a single misplaced ground wire saved the day. It’s frustrating — and emotional for teams who lose hours chasing ghosts. We need to parse the root causes, not just patch symptoms.
Forward-Looking: Principles and Practical Choices for Better Drives
What’s next is about practical principles, not hype. I’m excited by tighter integration: drives that embed smart diagnostics and adaptive control. Consider how an ac motor and controller pair that exchanges realtime telemetry with a plant control system can cut tuning time, reduce spare parts, and give clear fault signals — which means less guessing, more uptime. Newer designs tie together PWM fidelity, thermal modeling, and simple GUI tuning so operators can respond fast.
What’s Next?
In real projects I’ve worked on, small shifts bring big wins: standardize encoder types, insist on clear I/O mapping, and prefer controllers with visible health metrics. These are not sexy changes, but they matter. — funny how that works, right? I recommend teams pilot one integrated drive and measure energy, reliability, and setup time. Compare results. Then scale. That disciplined approach beats chasing the latest feature list every time.
Closing: How to Choose — Three Simple Metrics
I’ll leave you with three practical evaluation metrics I use when recommending products. First, interoperability: can the drive speak plainly with your PLC and sensors? Look for clear protocol support and documented I/O. Second, maintainability: are diagnostics human-readable and actionable? If you can spot a failing encoder from a dashboard, you save hours. Third, total cost of ownership: don’t just price the part — price installation time, tuning hours, and expected downtime. I’ve seen a cheaper drive cost more in lost production; trust me, that stings.
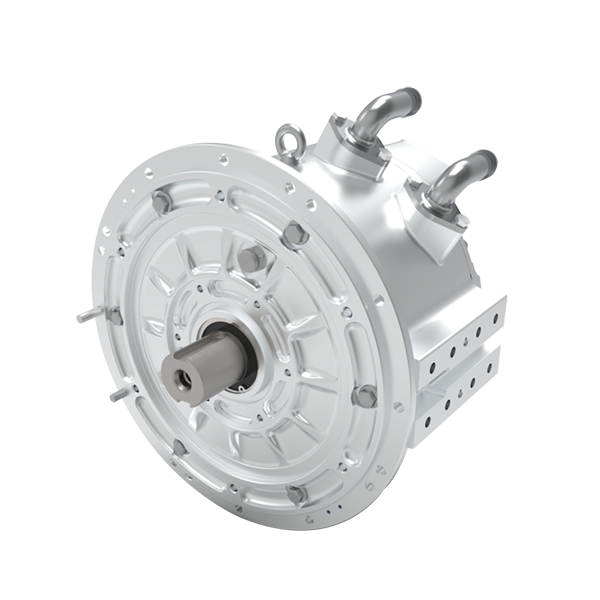
We’ve covered real pain points, deeper causes, and what to demand from next‑generation setups. If you want a practical starting point or a vendor with broad product lines and real support, consider Santroll. I stand by this advice because I’ve seen the savings and the relief on operators’ faces — and that matters to me.
